top of page
Master's Research Project
This was my Master's Research project at SJSU. The project was developing and integration a user fall detection and wheelbase countermotion response plan of a robotic rollator walker. The fall detection was done by analyzing user force/torque input onto the user handle and comparing to empirically derived fall threshold values. The walker normally uses the force/torque input as user intent detection for controlling the motorized wheels. The fall detection system would override the force/torque input to the wheel control, and enact a response motion plan to move the walker heading into the same direction as the user applied force vector in the XY plane, and enact a slight reversing motion to push the user upright and keep the walker in an ideal position of postural support.
Project type
Master's Research Project
Location
San Jose State University
GitHub Repository for Developed Code

01
Master's Research Project
01
Final_right
02
Final_left
03
Final_forward
04
Final_backward

05
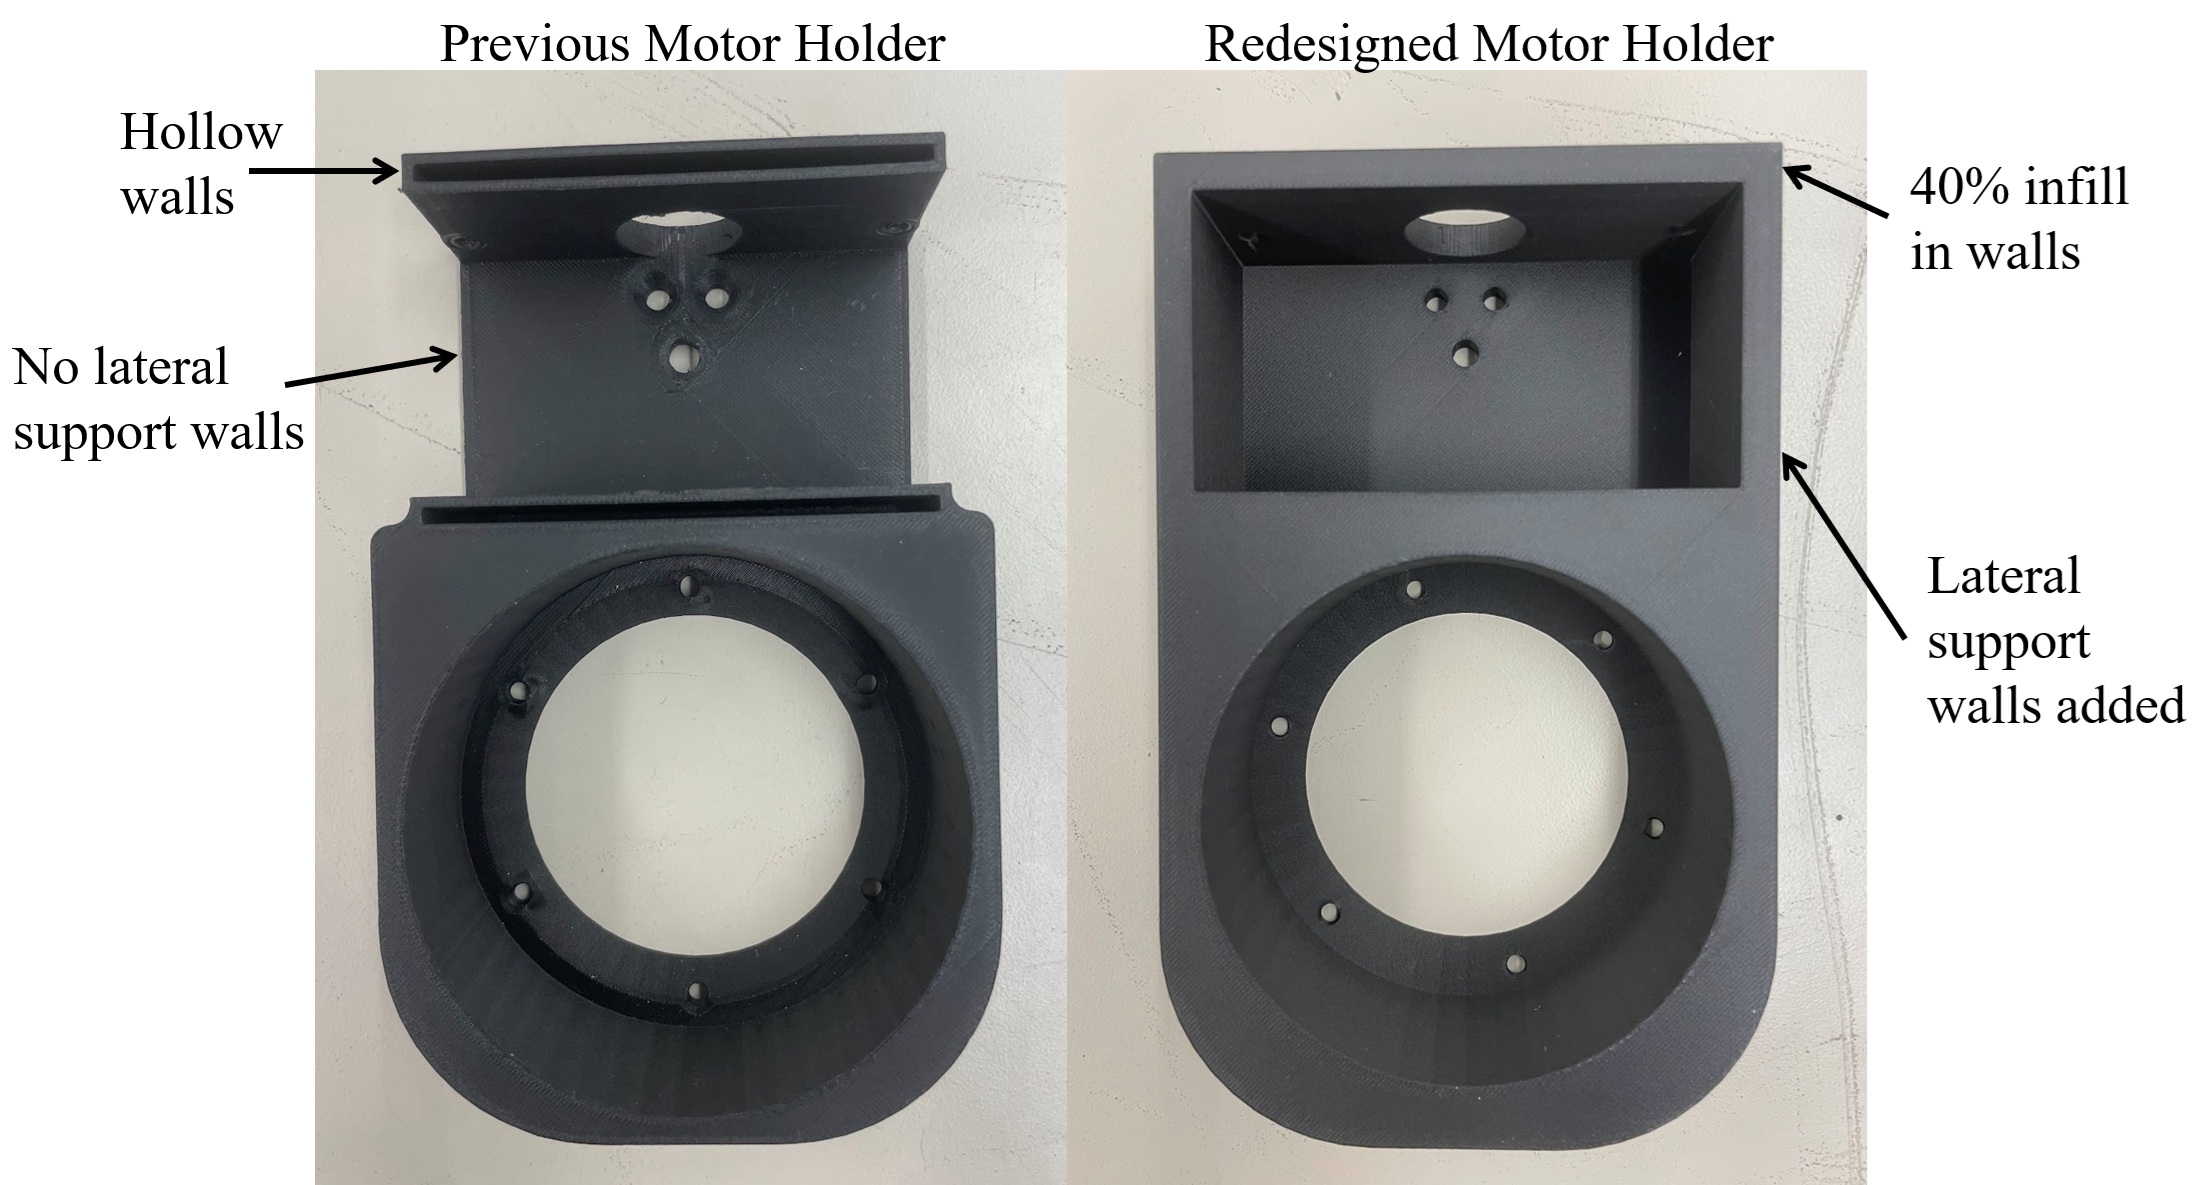
Motor holder redesign
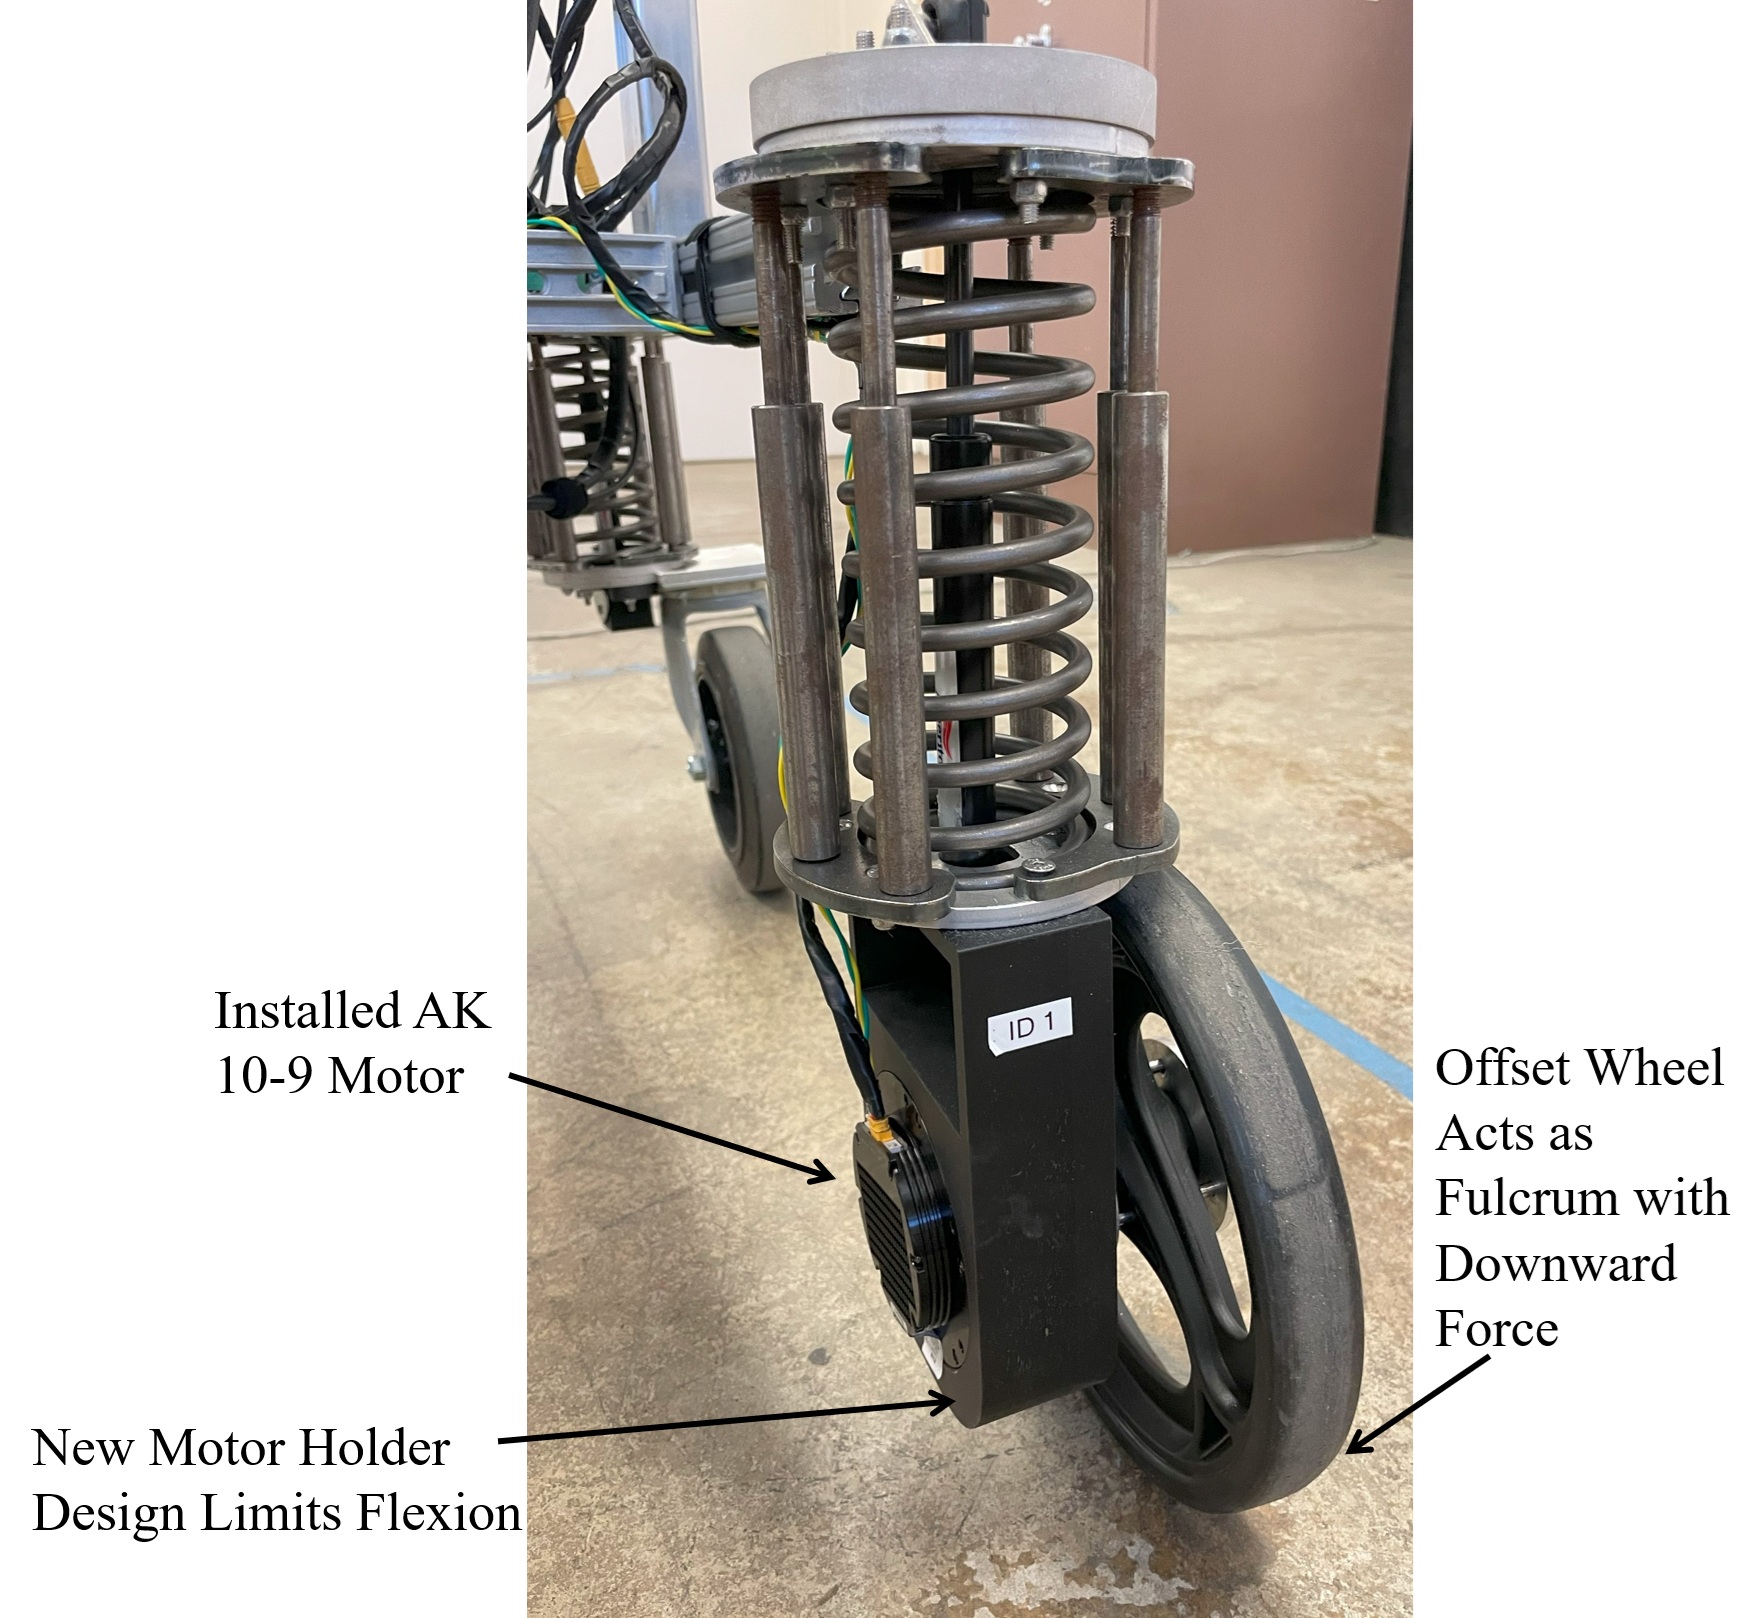
My Master’s project was implementing user fall detection and response motion to a robotic walker system that acted as a platform for several other student’s research project. As my project involved applying sudden force impulses that the original design did not account for, I had to redesign the motor holder. As previously designed, the motor holder allowed for flexion with sudden downward force that the suspension added to during the rebound. To prevent the motor holder from yielding, I redesigned the part to add lateral support, and increased the 3D printing infill to prevent the flexion and damage during the testing of my research project

06
New motor holder installed
bottom of page